 LYNXSPACE
Programme · Flight computer
LYNXYNAV V6.1
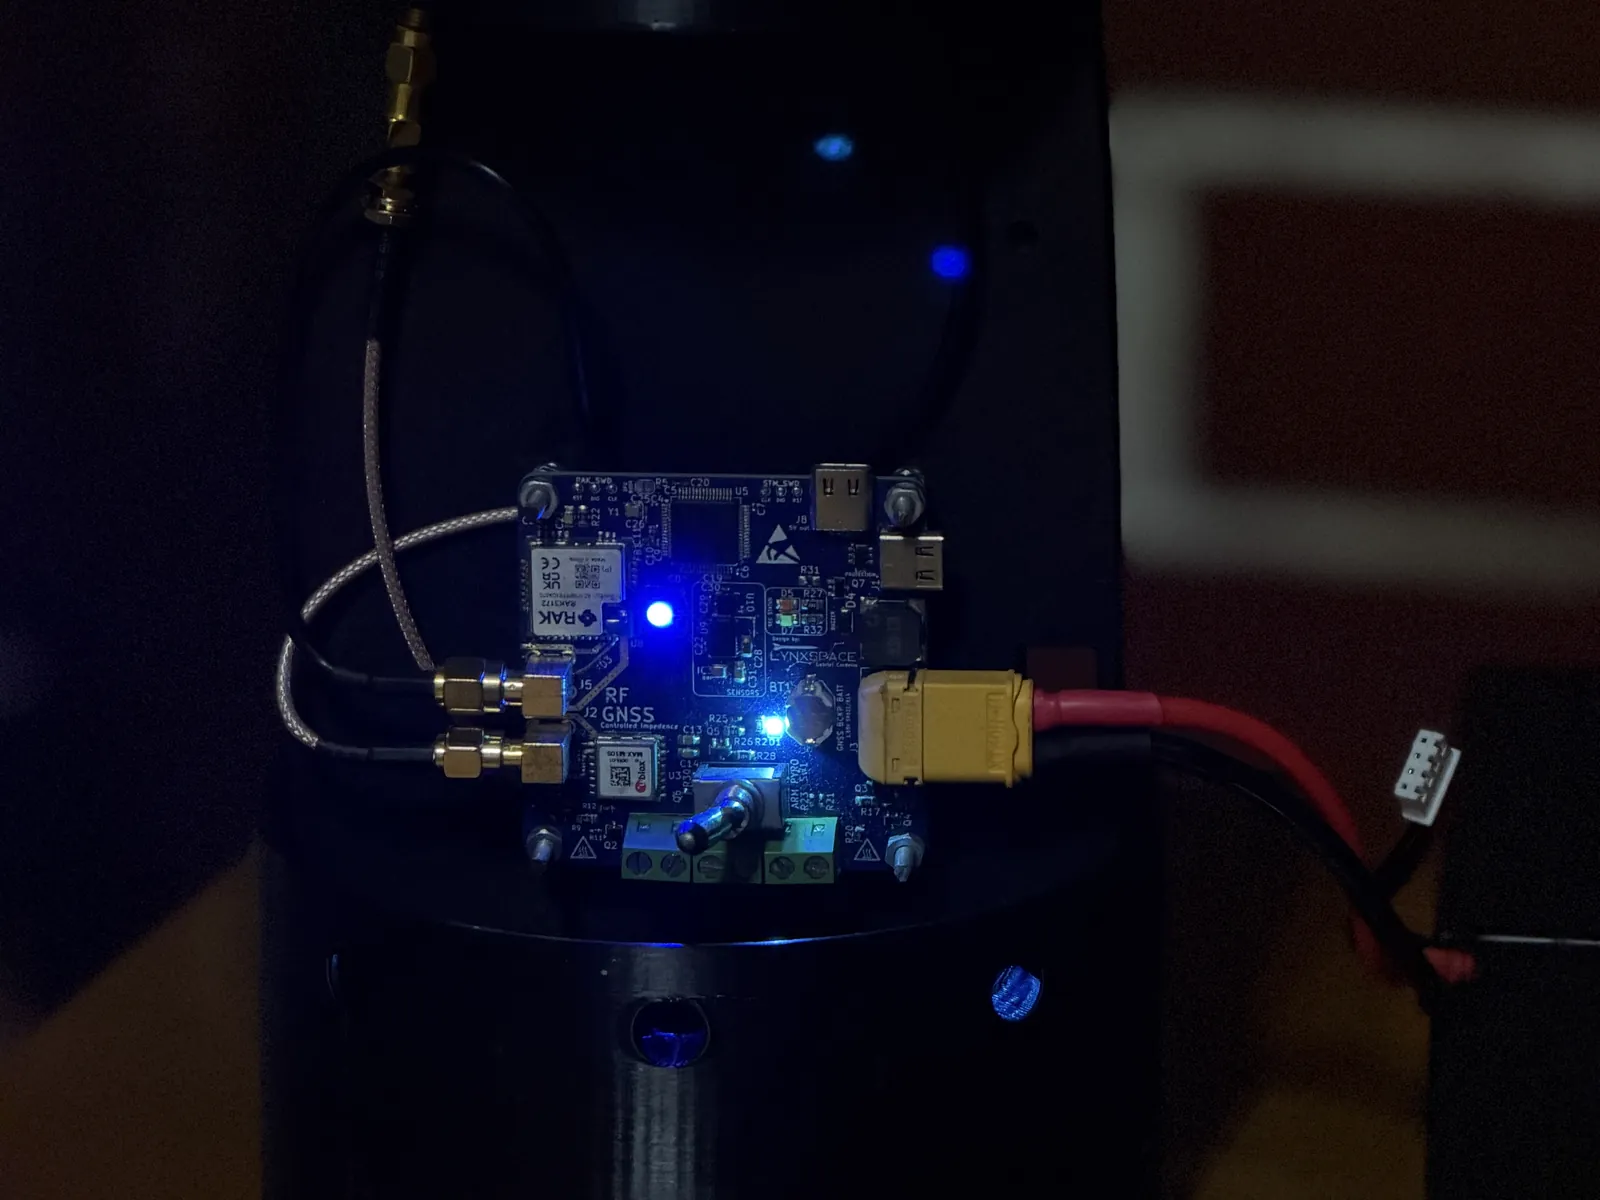
High power rocket flight computer with three pyro channels, equally usable for model rocketry. Telemetry, onboard control logic and campaign data logging on one 60 mm board.
| Class | High power rocket flight computer |
|---|---|
| Processor | STM32H563RIT6 |
| Sensors | Dual IMU, barometer, GNSS |
| Radio | 433 / 868 MHz |
| Validation | Hardware-in-the-loop, on the bench |
| First flight | Lynxrocket V5, Q3–Q4 2026 |
- Pyro channels
- 3
- Onboard logging
- 16MB
- Board mass
- 80g
- Nominal current
- 40mA at 12 V LiPo
Programme
The Flight Computer
V6.1 has not flown, because no Lynxrocket has. Flight Campaign Alpha is the first flight for the vehicle and for the board at the same time.
Reference sheet
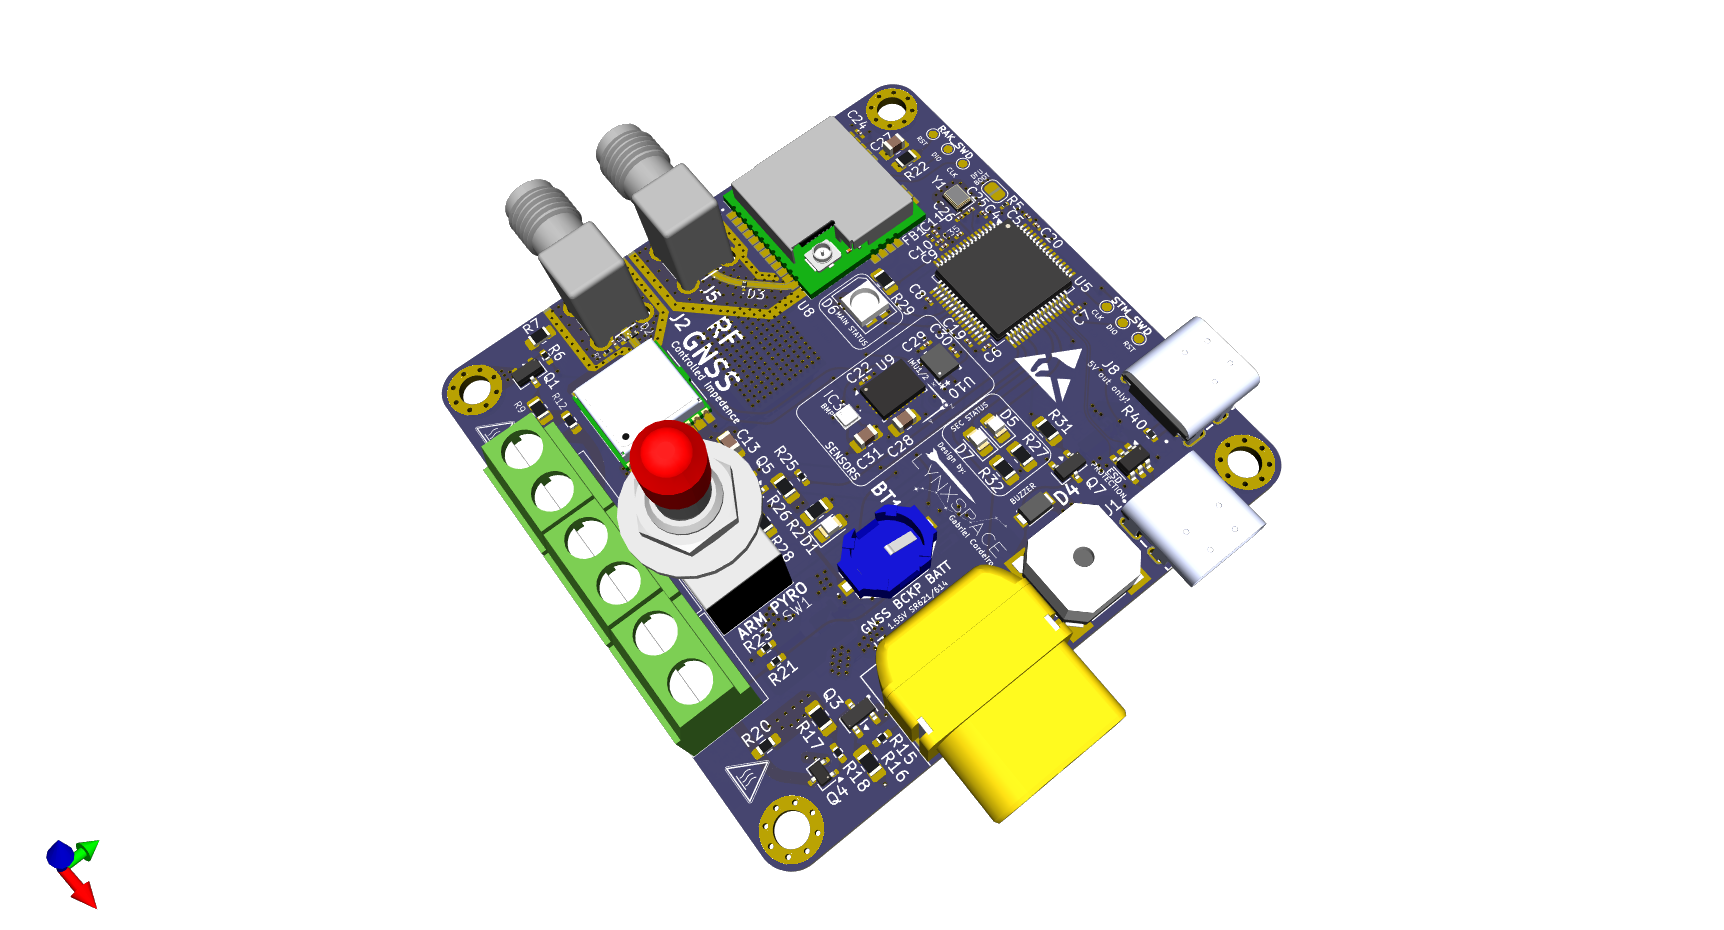
LynxYNav V6.1 specification
| MCU | STM32H563RIT6 |
|---|---|
| Sensors | Dual IMU, barometer, GNSS |
| Onboard processing | Sensor fusion with fault flags |
| Logging | 16 MB onboard |
| Log rate | 50 Hz |
| Input | 5–12 V DC |
|---|---|
| Connectors | XT60F, and USB-C |
| Nominal current | 40 mA at 12 V LiPo |
| At pyro deployment | 1 A |
| Pyro channels | 3 |
| Debug | SWD |
| Data | USB-C |
| Bands | 433 / 868 MHz |
|---|---|
| Regional profile | EU868 |
| Channel access | Listen-before-talk |
| GNSS fix | 3D, 25 satellites |
| Size | 60 × 60 × 2 mm |
|---|---|
| Mass | 80 g |
| Mounting | 4 plated M3 holes |
| Operating temperature | −20 °C to +65 °C |
Validation
What the board has been through
- Q1 2026Complete
Bench validation
Hardware-in-the-loop testing, sensor fusion calibration and communication stress tests.
- Q2 2026Complete
Integrated ground tests
Run inside the Lynxrocket V5 airframe through recovery deployment drills and a full dress rehearsal.
- Q3–Q4 2026Next
First flight
Flight Campaign Alpha, on Lynxrocket V5. The first logged flight data the board has produced.
Contact
Two companion boards
A ground station interface board and a pitot-static sensor board are available alongside V6.1. Send your mission constraints and the timeline you are working to.